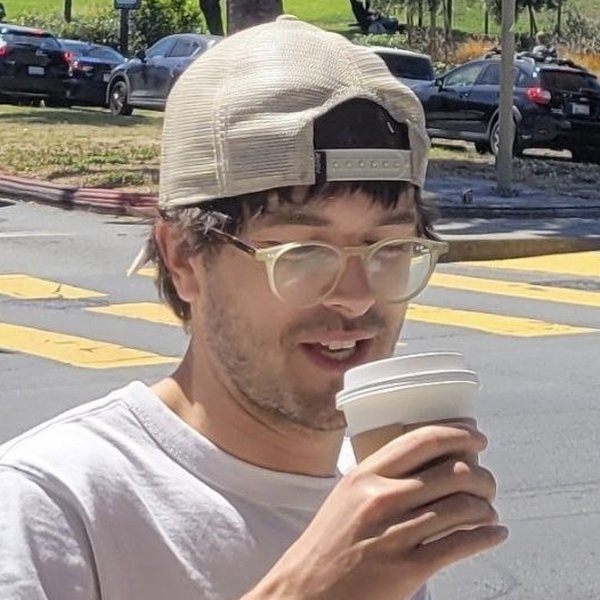
Julien Mellet is a robotics engineer
building drones for physical interaction: aerial robots that
don't just fly and look, but touch, push and work on the world around them. His PhD in Robotics at the
PRISMA Lab (University of Naples
Federico II), done as a
Marie Skłodowska-Curie fellow, received the
i-PhD Grand Prix 2025.
In 2026 he
was named one of
Le Point's Top 100 French Inventors.
Today he builds robots as products, both for education, making robotics and programming
accessible to kids, and for industry, with aerial robots for the inspection and maintenance of
industrial assets.
Short bio
I’ve always liked building things that move, and flying machines especially. After two intense years of
maths and physics in preparatory school in Angers, I joined
INSA Centre Val de Loire
(Blois, France) to study systems engineering.
In 2018 I spent a spring and summer at
ISIR – Sorbonne University (Paris) building the
Hive Tracker, a cheap sub-millimetric 3D motion-capture device that fuses IMU and optical
localization. Then I left for China to do an MSc in Aerospace Engineering at
Northwestern Polytechnical University (Xi’an), where my master's thesis was on
fast autonomous drone landing. I also filed my first patent there, a
flexible damping landing gear. In between, I spent a summer at
Thales writing a ground
control station for drone swarms, and hacked on side projects with friends, like an electric
thrust-vectoring rocket (the eRocket). During my studies I also started an entrepreneurship project,
ilo, an educational robot that kids program by simply taking a photo of the
path they plan. It won the
Prix Pépite for student entrepreneurs.
In 2021 I moved to Naples for a PhD at the
PRISMA Lab (University of Naples Federico II),
as a Marie Skłodowska-Curie fellow in the European project
AERO-TRAIN. I worked on aerial robots
that don't just fly and look, but actually
touch things. That meant omnidirectional drones, soft and flexible arms, and haptic
joysticks so a human can feel what the robot feels. The
thesis
received the i-PhD Grand Prix 2025.
ilo then grew into a real company, which I co-founded and where I built the team designing and
manufacturing the robots. Since then I've kept doing what I like most: turning research into robots
people can actually use, in classrooms as well as on industrial sites.
Publications
Manipulator Design and Target Localization for Safe Aerial Physical Inspection Mission
Andrea Berra,
J. Mellet, Viswa Narayanan Sankaranarayanan, Achilleas Santi Seisa, Udayanga GWKN Gamage, Sumeet Gajanan Satpute, Fabio Ruggiero, Vincenzo Lippiello, Silvia Tolu, Matteo Fumagalli, George Nikolakopoulos, Miguel Angel Trujillo Soto, Guillermo Heredia
TechRxiv preprint, 2025
[Paper] [PDF]
Assisted Physical Interaction: Autonomous Aerial Robots with Neural Network Detection, Navigation, and Safety Layers
Andrea Berra, Viswa Narayanan Sankaranarayanan, Achilleas Santi Seisa,
J. Mellet, Udayanga GWKN Gamage, Sumeet Gajanan Satpute, Fabio Ruggiero, Vincenzo Lippiello, Silvia Tolu, Matteo Fumagalli, George Nikolakopoulos, Miguel Ángel Trujillo Soto, Guillermo Heredia
International Conference on Unmanned Aircraft Systems (ICUAS), IEEE, pp. 1354–1361, 2024
[Paper] [PDF (arXiv)]
Design of a Flexible Robot Arm for Safe Aerial Physical Interaction
J. Mellet, Andrea Berra, Achilleas Santi Seisa, Viswa Sankaranarayanan, Udayanga GWKN Gamage, Miguel Ángel Trujillo Soto, Guillermo Heredia, George Nikolakopoulos, Vincenzo Lippiello, Fabio Ruggiero
IEEE 7th International Conference on Soft Robotics (RoboSoft), pp. 1048–1053, 2024
[Paper] [PDF (arXiv)]